I'm a PhD student in the Ohtsuki Laboratory at Keio University, working with Prof. Tomoaki Ohtsuki, where I also earned my M.Eng. I hold a B.Eng. in Information Security from Hefei University of Technology.
My keywords: autonomous driving, multimodal learning, vision-language models (VLMs), embodied intelligence.
Latest News
September 2026
Accepted to NeurIPS 2026
Our paper “Selection, Not Fusion: Radar-Modulated State Space Models for Radar-Camera Depth Estimation” has been accepted to NeurIPS 2026.
July 2026
New Preprint on arXiv
Our paper “RePos: Relative-to-Absolute Output Factorization for Cross-Environment WiFi-Based 3D Human Pose Estimation” is now available on arXiv.
May 2026
New Preprint on arXiv
Our paper “Selection, Not Fusion: Radar-Modulated State Space Models for Radar-Camera Depth Estimation” is now available on arXiv.
2025
Accepted to IEEE IoT Journal
Our paper “Loss-adapter: Addressing network packet loss in distributed inference for lossy IoT environments” has been accepted to the IEEE Internet of Things Journal.
2025
Accepted to IEEE ICC 2025
Our paper “A Plug-and-Play Module for Enhancing Fault-Tolerant Distributed Inference Based on Gaussian Dropout” has been accepted to ICC 2025, the IEEE International Conference on Communications.
Publications
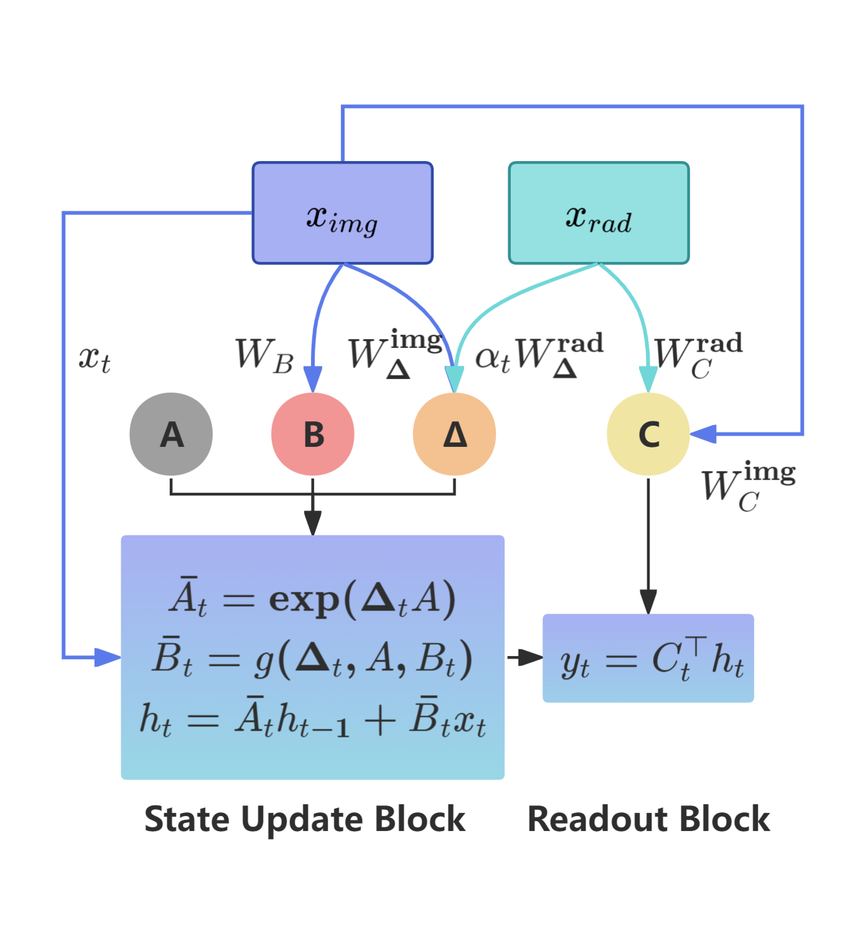
Selection, Not Fusion: Radar-Modulated State Space Models for Radar-Camera Depth Estimation
Zhangcheng Hou, Tomoaki OhtsukiNeurIPS '26
Injecting radar features inside the Mamba selective state-space (modulating Δ and C) rather than only pre-blending modalities, for more robust radar–camera depth estimation.
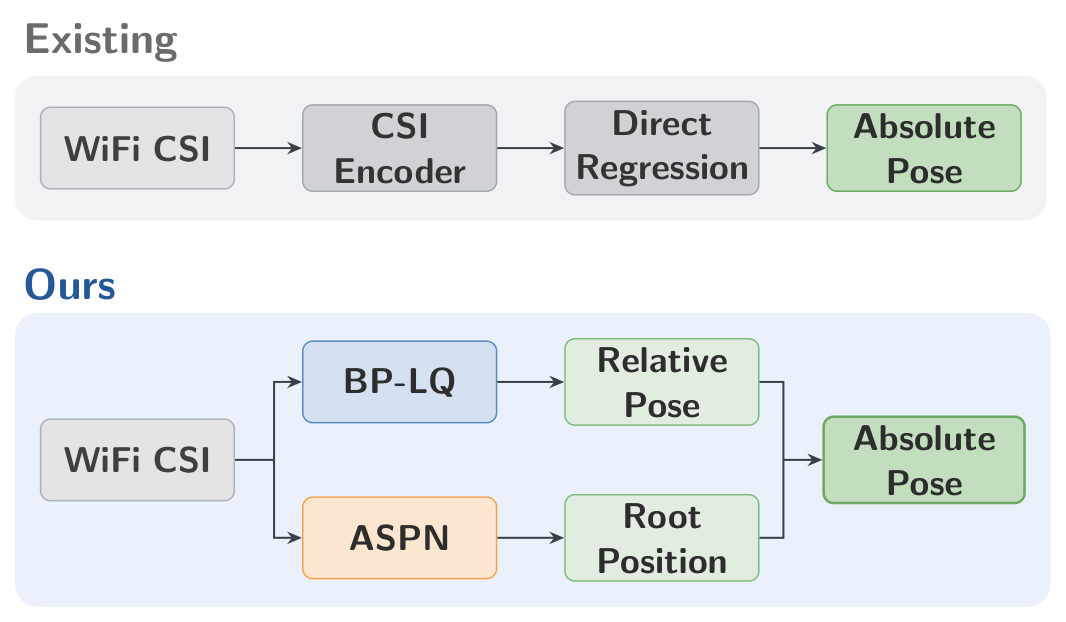
RePos: Relative-to-Absolute Output Factorization for Cross-Environment WiFi-Based 3D Human Pose Estimation
Zhangcheng Hou, Tomoaki OhtsukiarXiv '26
Factorizing WiFi 3D pose into a room-agnostic relative pose and a room-specific root position, so body structure transfers across unseen environments while a separate branch handles localization.
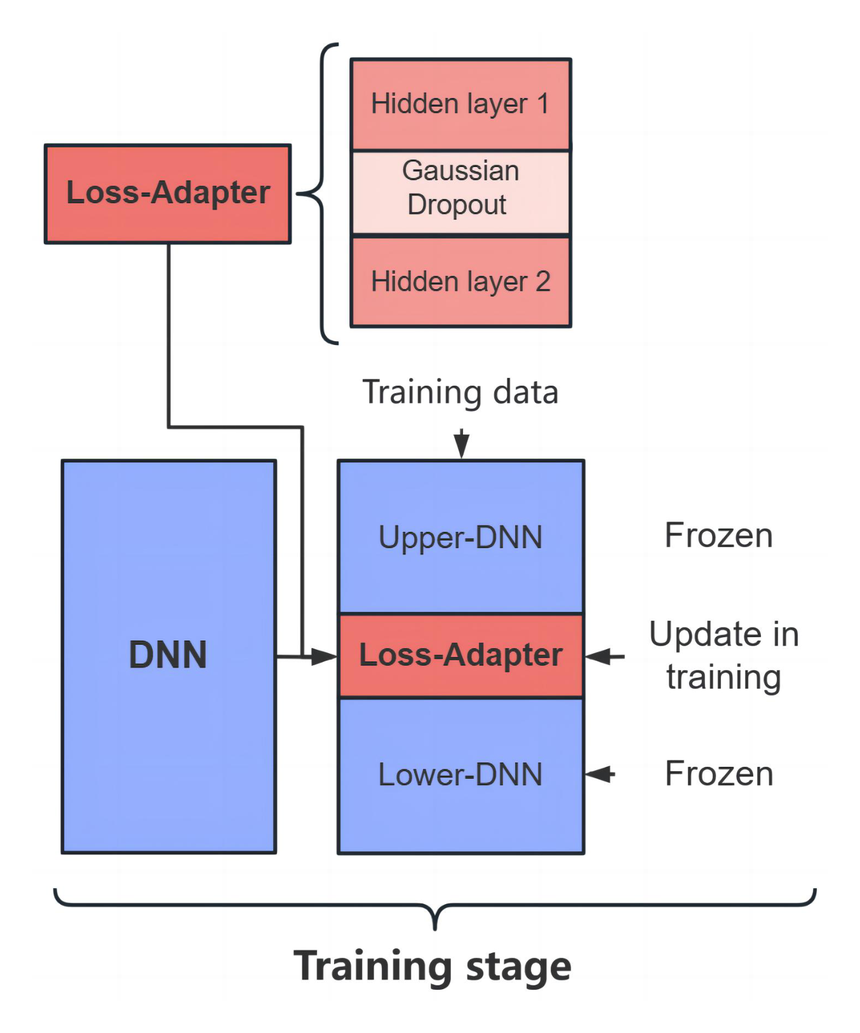
Loss-adapter: Addressing Network Packet Loss in Distributed Inference for Lossy IoT Environments
Zhangcheng Hou, Tomoaki OhtsukiIEEE IoT-J '25
A method that keeps split / distributed neural inference accurate when intermediate feature packets are dropped over unreliable IoT networks.
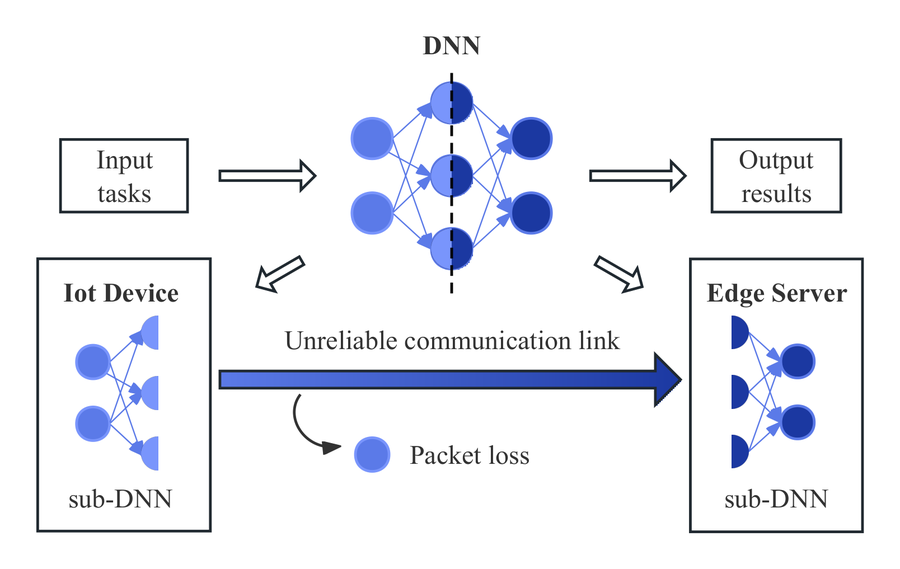
A Plug-and-Play Module for Enhancing Fault-Tolerant Distributed Inference Based on Gaussian Dropout
Zhangcheng Hou, Tomoaki OhtsukiIEEE ICC '25
A drop-in module that improves the fault tolerance of distributed inference by training models to withstand feature corruption with Gaussian dropout.